I’m a fourth-year Ph.D. candidate in the Department of Computer Science at Brown University, advised by Prof. Srinath Sridhar. Previously, I graduated from the International Institute of Information Technology Hyderabad (IIIT-H) with an MS in Computer Science, where I worked with Prof. K Madhava Krishna.
My research focuses on enabling general-purpose robots to acquire interaction-rich motor behaviors for diverse tasks in the physical world. I study generative models and physics-aware policy learning to develop robust, adaptable skills across multiple embodiments. I intend to build scalable robot learning systems that integrate perception and physical interaction dynamics to enable whole-body humanoid control and dexterous manipulation, allowing robots to reliably perform complex tasks in unstructured real-world environments.
News
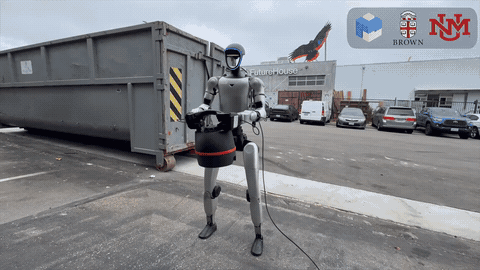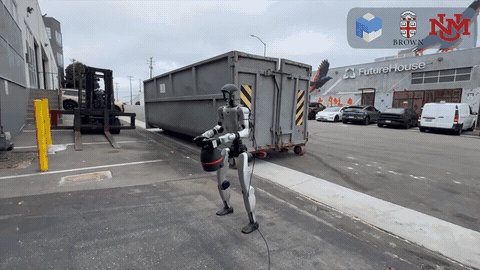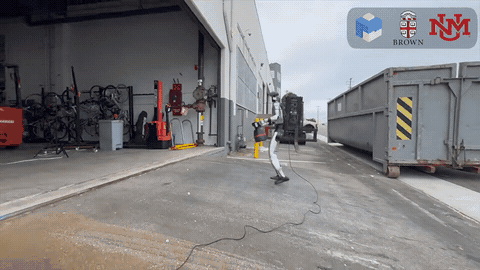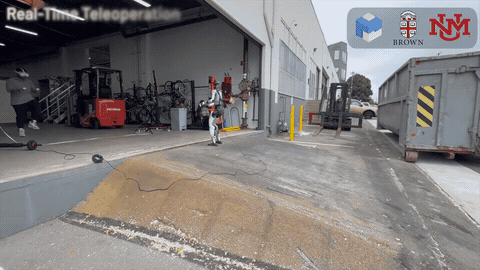
| Oct 2026 | Introducing BRACE! |
|---|---|
| Aug 2026 | I’m co-organizing the NeuRo-SymBolic World Models (RoBoWoMo) workshop, bringing together neural and symbolic perspectives on world models for robotics. |
| Jun 2026 | DreamControl-v2 accepted at IROS 2026! See you all in Pittsburgh! |
| Jun 2026 | Started my summer internship at Multiply Labs. |
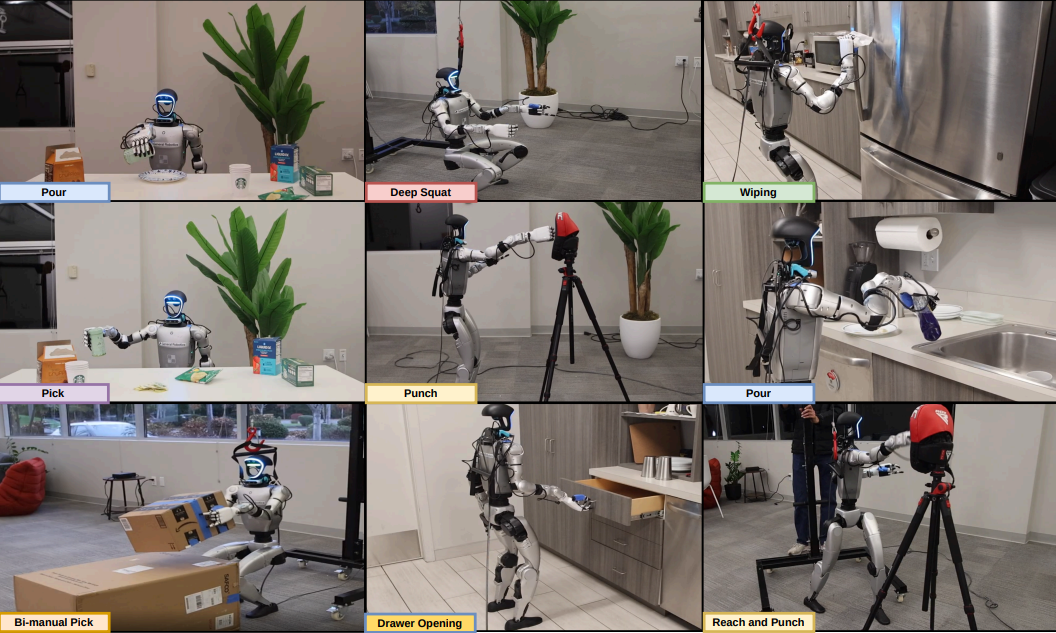
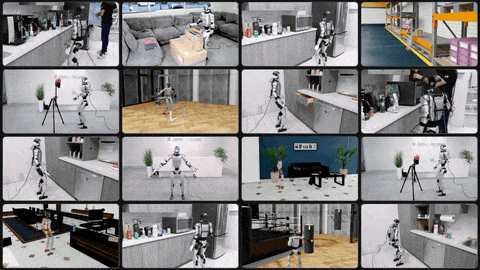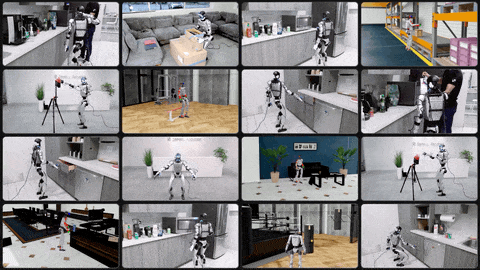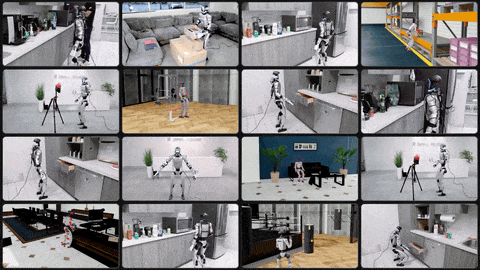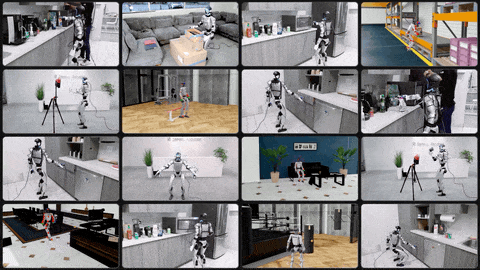
| Sep/Dec 2025 | Introducing DreamControl/v2, scalable generative priors for whole-body humanoid interaction tasks. |
Older news (6)
| Jun 2025 | Started a summer internship at General Robotics, working on humanoid robots. |
|---|---|
| Apr 2025 | Recognized as a Outstanding Reviewer for CVPR2025 . |
| Jan 2025 | MotionGlot is Accepted at ICRA 2025. |
| Aug 2023 | Started my PhD at Brown CS after graduating from IIIT-H with an MS in CS. |
| Aug 2023 | Our work FinderNet is accepted at WACV2024 in the first round |
| Jul 2022 | Stated with the SGI program organized by MIT |
Selected publications
Awards and grants
- June 2025 NVIDIA Academic Grant Program
“Large Action Models: A Cross-Embodied Model for Dexterous Manipulation.” Co-written with Srinath Sridhar and Tao Lu.
- May 2025 Outstanding Reviewer, CVPR 2025
- April 2025 Doctoral Consortium, ICRA 2025 Oral Highlight
- 2021–2023 Research Fellowship, IIIT Hyderabad
- March 2022 IEEE RAS Travel Grant, ICRA 2022
Press
MotionGlot
- December 2025
The Boston Globe · December 15, 2025
- May 2025
Brown University News · May 8, 2025
Invited talks
- October 2026 BRACE: Adapting Whole-Body References for Force and Terrain Aware Humanoid Motion Tracking
Invited talk · General Robotics
- April 2025 Large Action Models: Towards Building a Foundation Model for Cross-Embodied Action Generation
Invited talk · Robotics and AI Institute (RAI)
Service
Reviewing
- Conferences: CoRL, ICRA, IROS, CVPR, and ECCV.
- Journal: IEEE Robotics and Automation Letters (RA-L).
Admissions
- January 2026 CS Ph.D. Application Reader
Brown University