publications

publications by categories in reversed chronological order. generated by jekyll-scholar.

2026

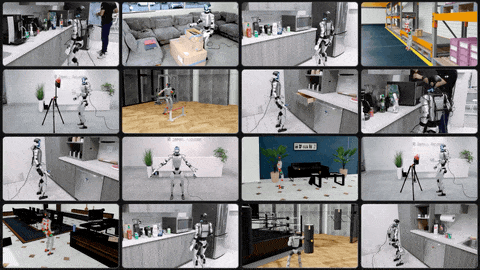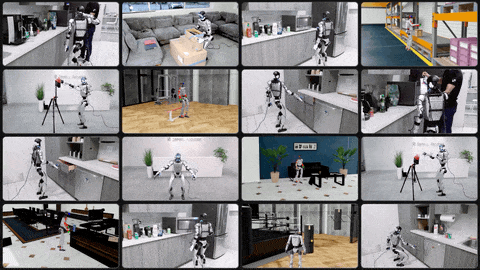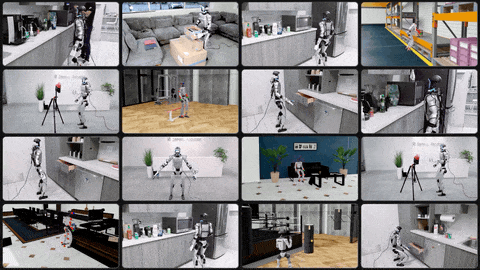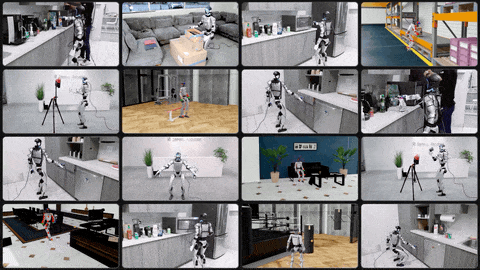
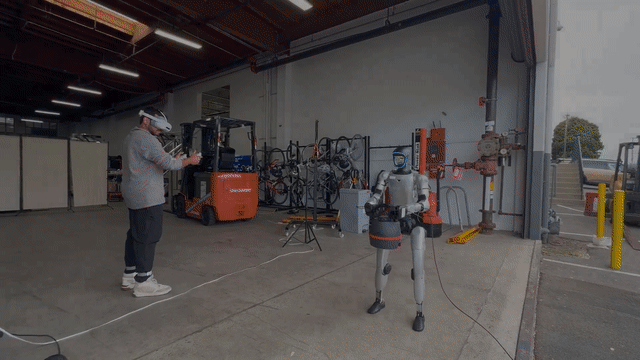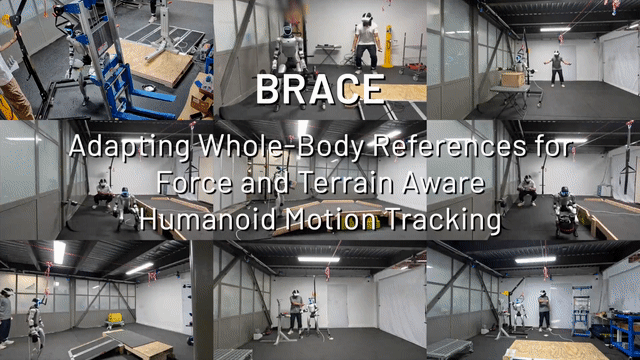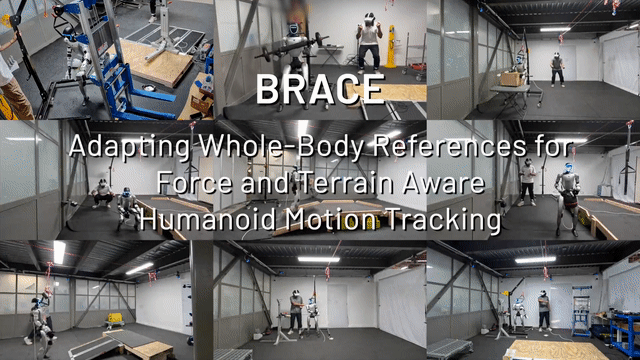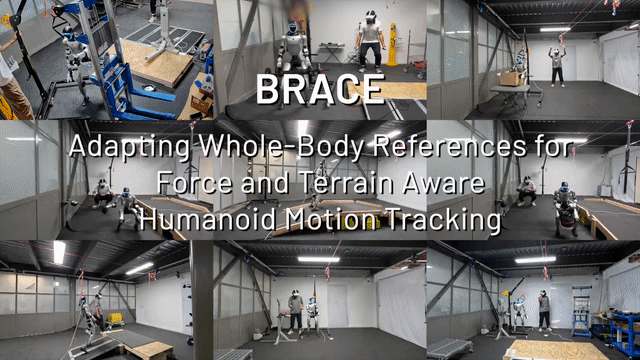
  1. brace.gif
    BRACE: Adapting Whole-Body References for Force and Terrain Aware Humanoid Motion Tracking
    Sudarshan Harithas, Chen Yu, Juan Borbon, Shubhankar Mondal, Winston Zha, Srinath Sridhar, Dingqi Zhang, and Jiuguang Wang
    arXiv preprint arXiv:2610.07052, 2026
  2. dreamcontrol_v2.png
    DreamControl-v2: Simpler and Scalable Autonomous Humanoid Skills via Trainable Guided Diffusion Priors.
    Sdarshan S. Harithas, Sangkyung Kwak, Pushkal Katara, Srujan Deolasee, Dvij Kalaria, Srinath Sridhar, Sai Vemprala, Ashish Kapoor, and Jonathan Chung-Kuan Huang.
    In IROS 2026
  3. dream_control.gif
    DreamControl: Human-Inspired Whole-Body Humanoid Control for Scene Interaction via Guided Diffusion
    Dvij Kalaria, Sudarshan S. Harithas, Pushkal Katara, Sangkyung Kwak, Sarthak Bhagat, Shankar Sastry, Srinath Sridhar, Sai H. Vemprala, Ashish Kapoor, and Jonathan Chung-Kuan Huang
    In ICRA 2026

2025

  1. motionglot.gif
    MotionGlot: A multi embodied Motion Generator.
    Sudarshan S Harithas, and Srinath Sridhar
    In ICRA 2025,
    Accepted at X-Embodiment Workshop CORL 2024
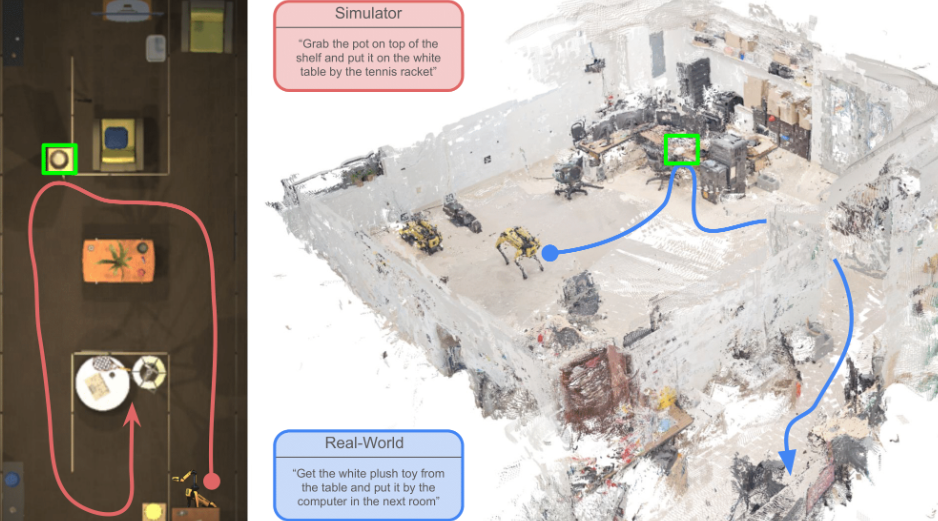
  2. lambda.png
    λ: A Benchmark for Data-Efficiency in Long-Horizon Indoor Mobile Manipulation Robotics
    2025

2024

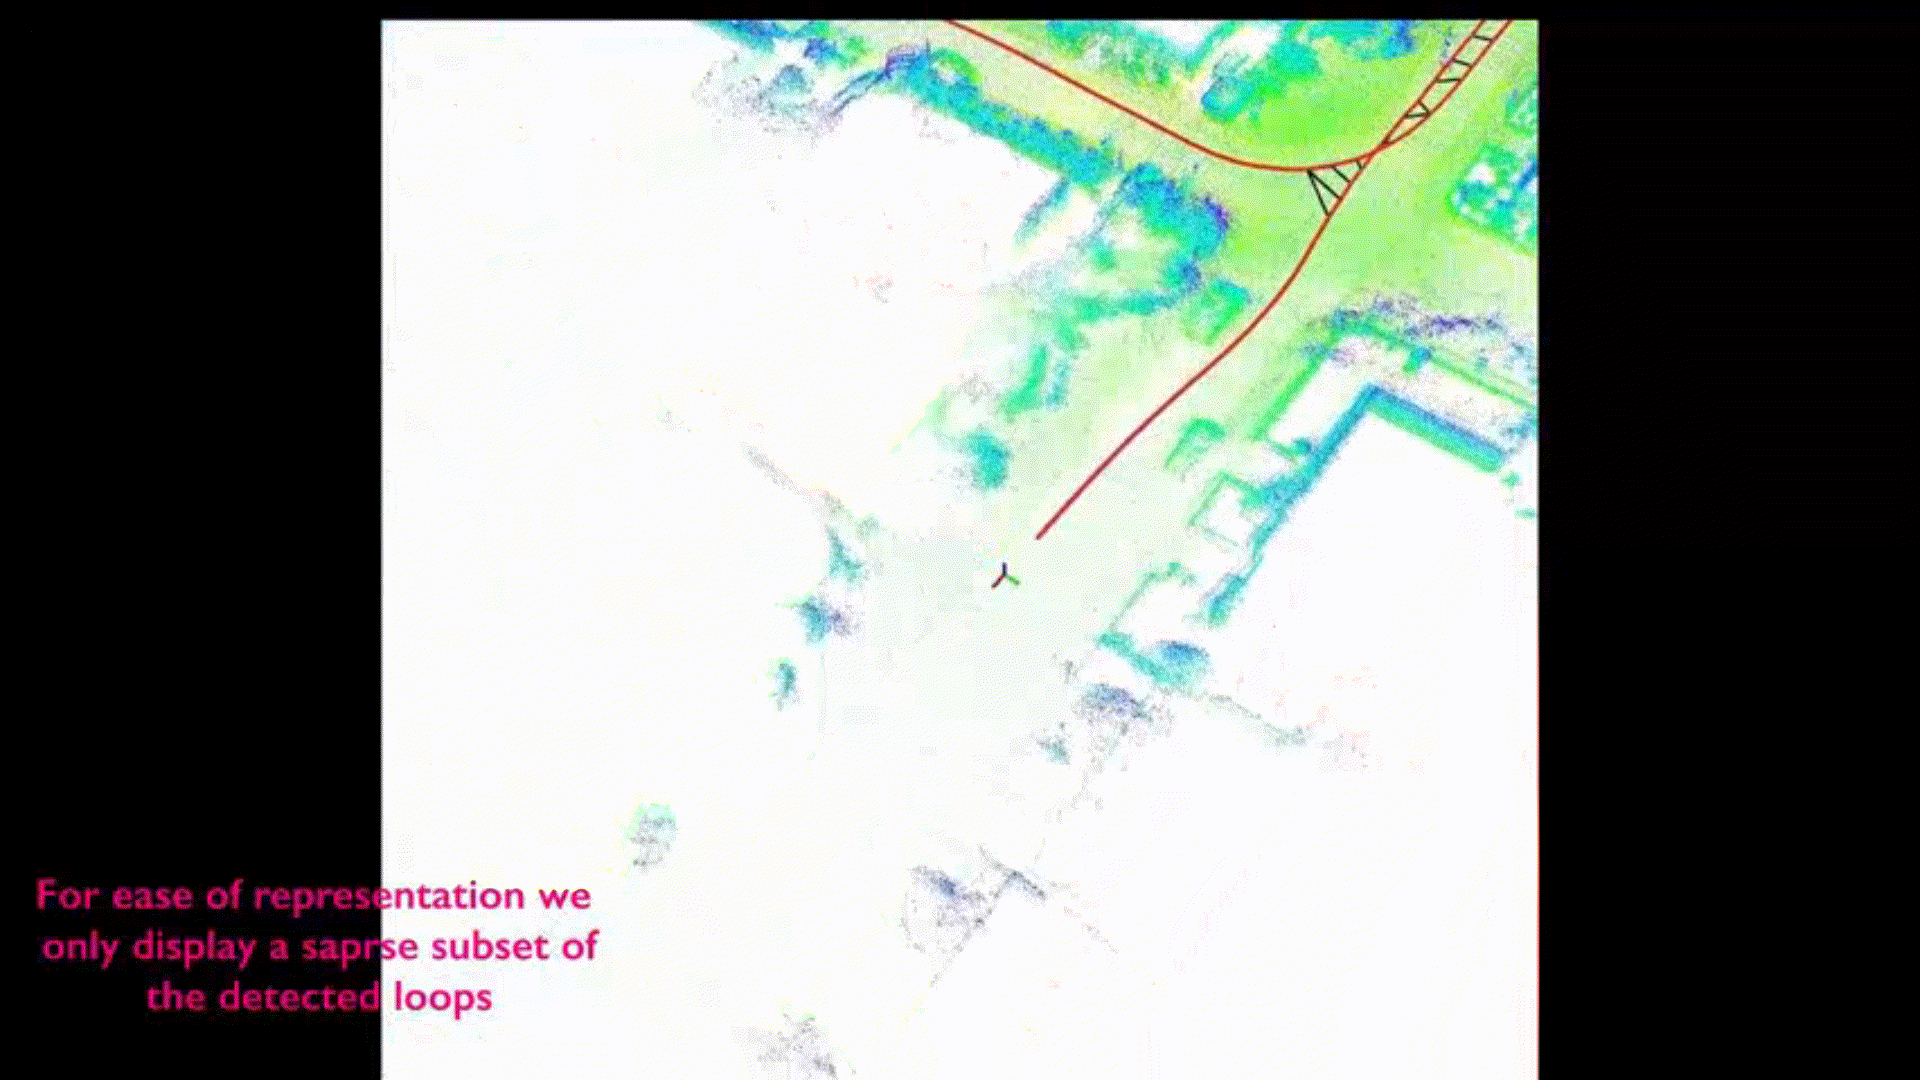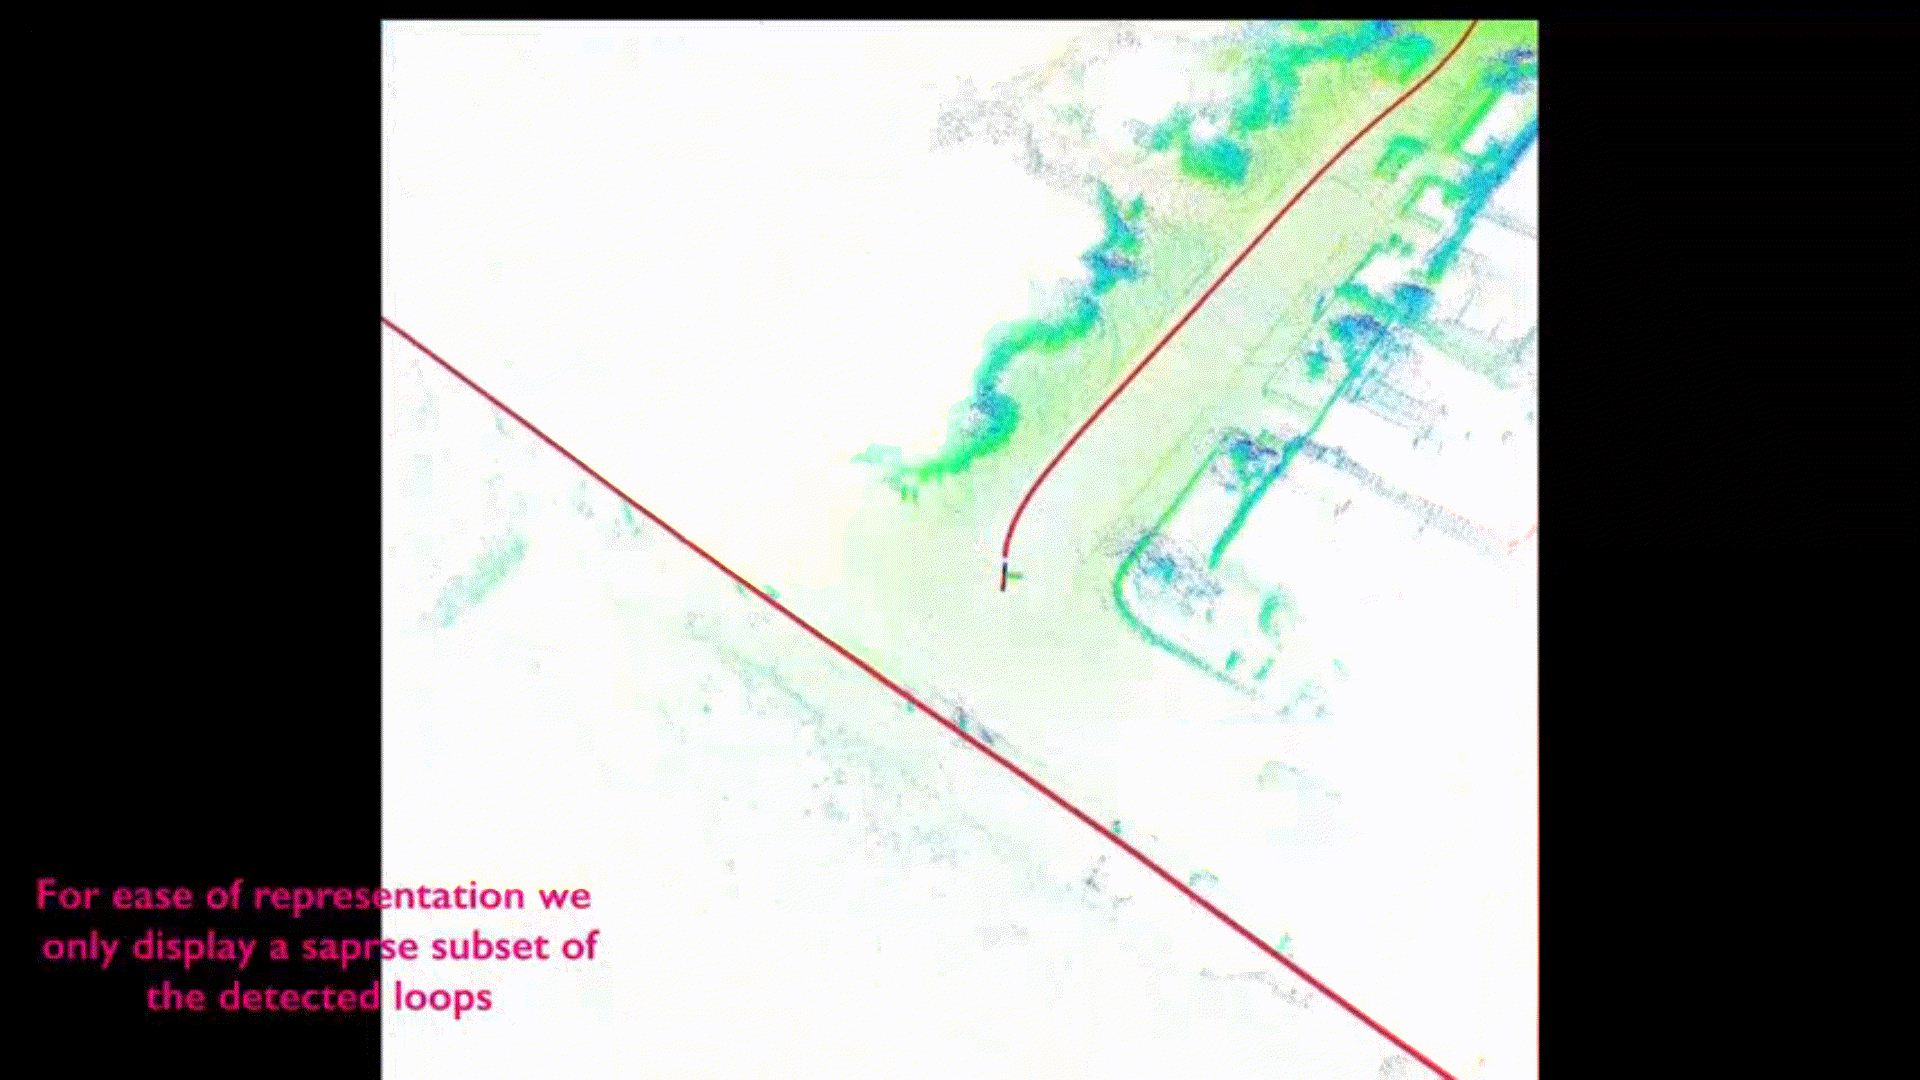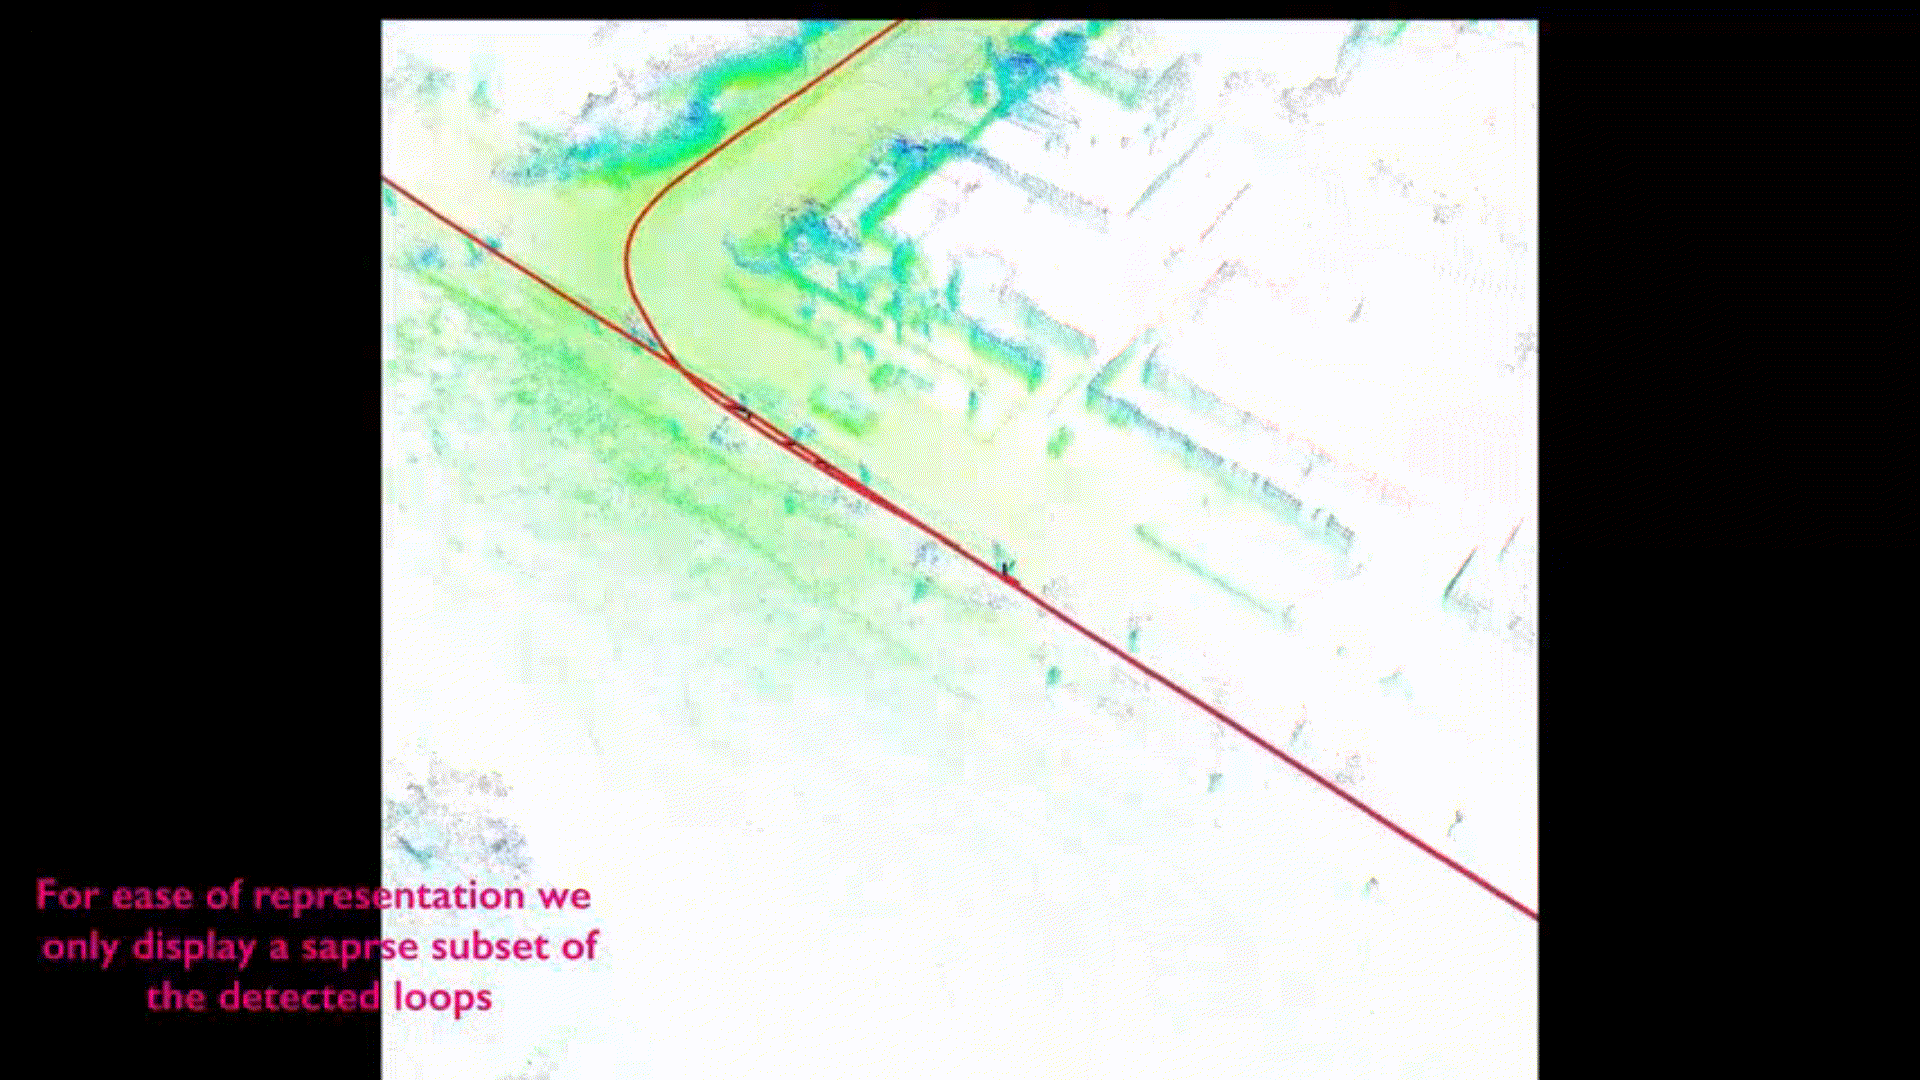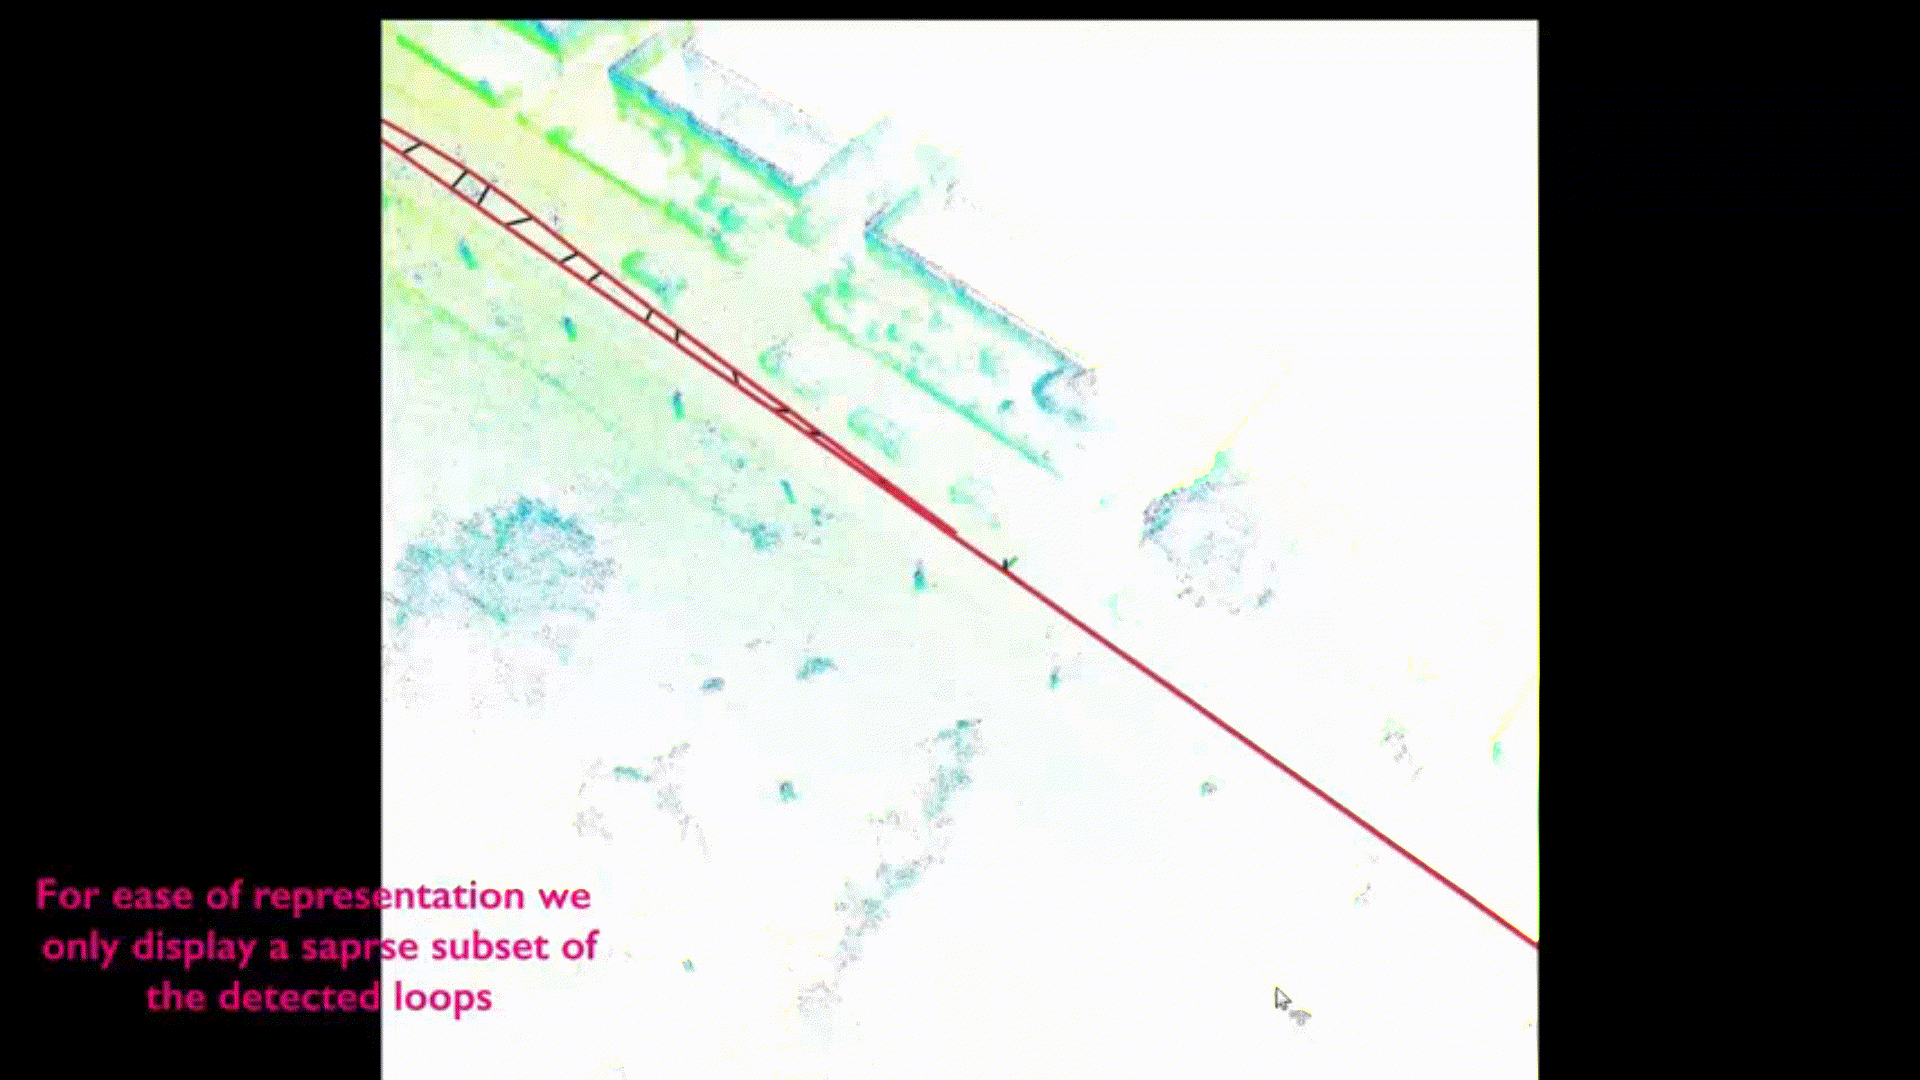
  1. ldc.gif
    FinderNet: A Data Augmentation Free Canonicalization aided Loop Detection and Closure technique for Point clouds in 6-DOF separation.
    Sudarshan S Harithas, Gurkirat Singh, Aneesh Chavan, Sarthak Sharma, Suraj Patni, Chetan Arora, and Madhava Krishna
    In Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision, 2024

2023

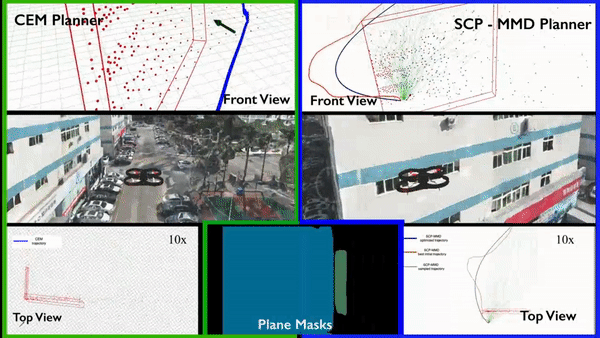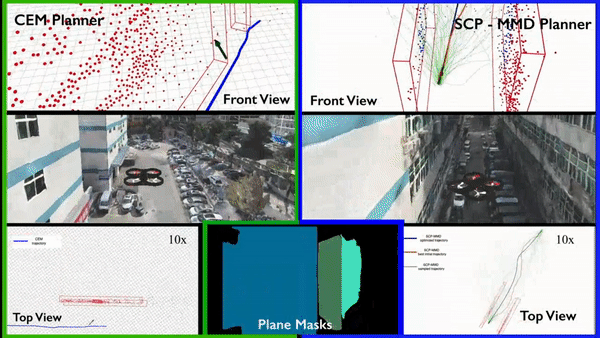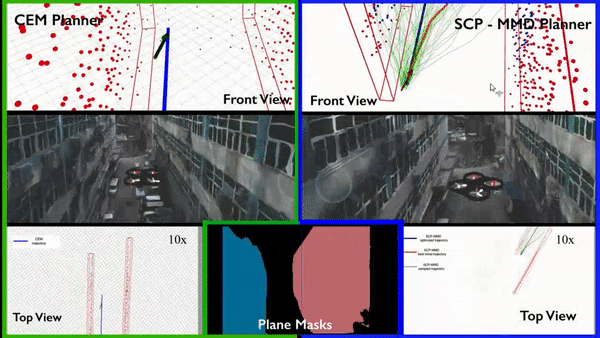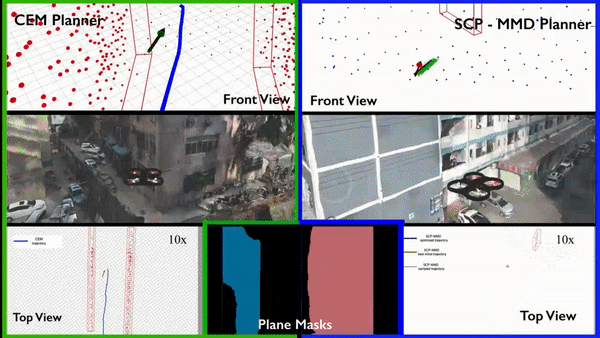
  1. SimulationUrbanFly.gif
    Urbanfly: Uncertainty-aware planning for navigation amongst high-rises with monocular visual-inertial slam maps
    Sudarshan S Harithas, Ayyappa Swamy Thatavarthy, Gurkirat Singh, Arun K Singh, and K Madhava Krishna
    In 2023 American Control Conference (ACC)

2022

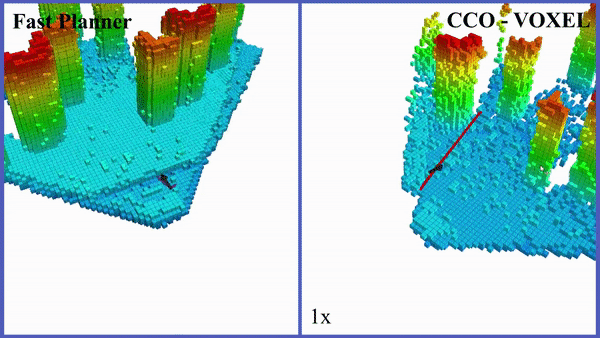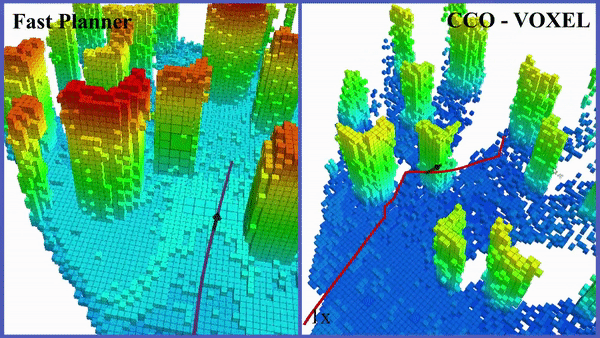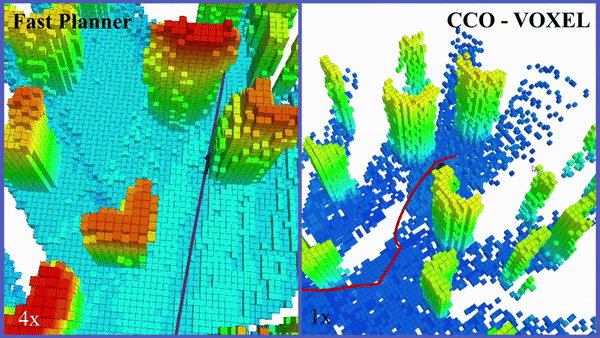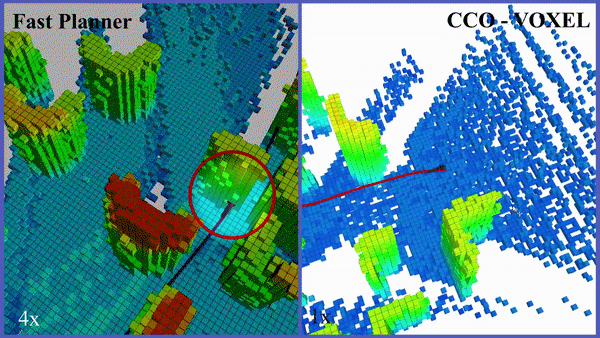
  1. simulation.gif
    Cco-voxel: Chance constrained optimization over uncertain voxel-grid representation for safe trajectory planning
    Sudarshan S Harithas, Rishabh Dev Yadav, Deepak Singh, Arun Kumar Singh, and K Madhava Krishna
    In 2022 International Conference on Robotics and Automation (ICRA)

2021

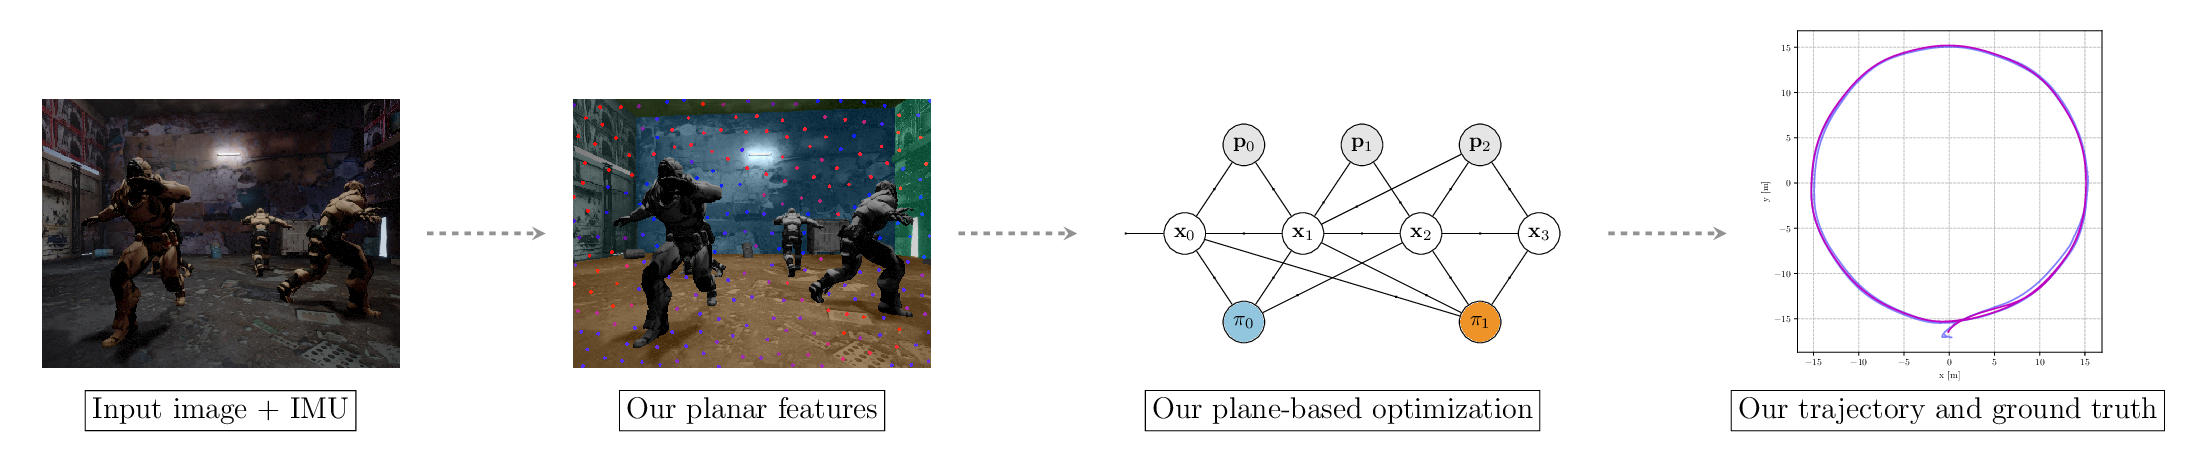
  1. rp_vio.png
    Rp-vio: Robust plane-based visual-inertial odometry for dynamic environments
    Karnik Ram, Chaitanya Kharyal, Sudarshan S Harithas, and K Madhava Krishna
    In 2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
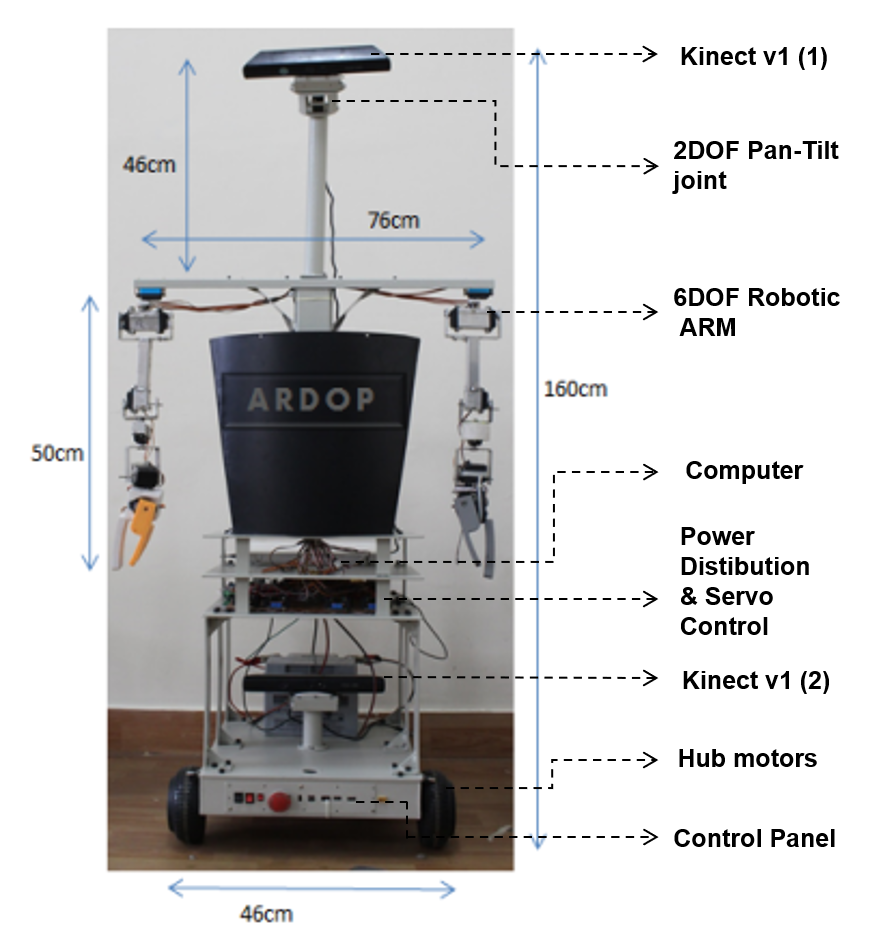
  2. ardop_description.png
    ARDOP: A Versatile Humanoid Robotic Research Platform
    Sudarshan S Harithas, and Harish V Mekali
    arXiv preprint arXiv:2108.07983, 2021